Why SO-101
SO-101 is designed as an accessible entry point into robotics: affordable hardware, open documentation, and a workflow that connects mechanical setup with data collection and learning.
ROBOTICS · AI · OPEN SOURCE
A hands-on build with Hugging Face's open-source robotic arm.
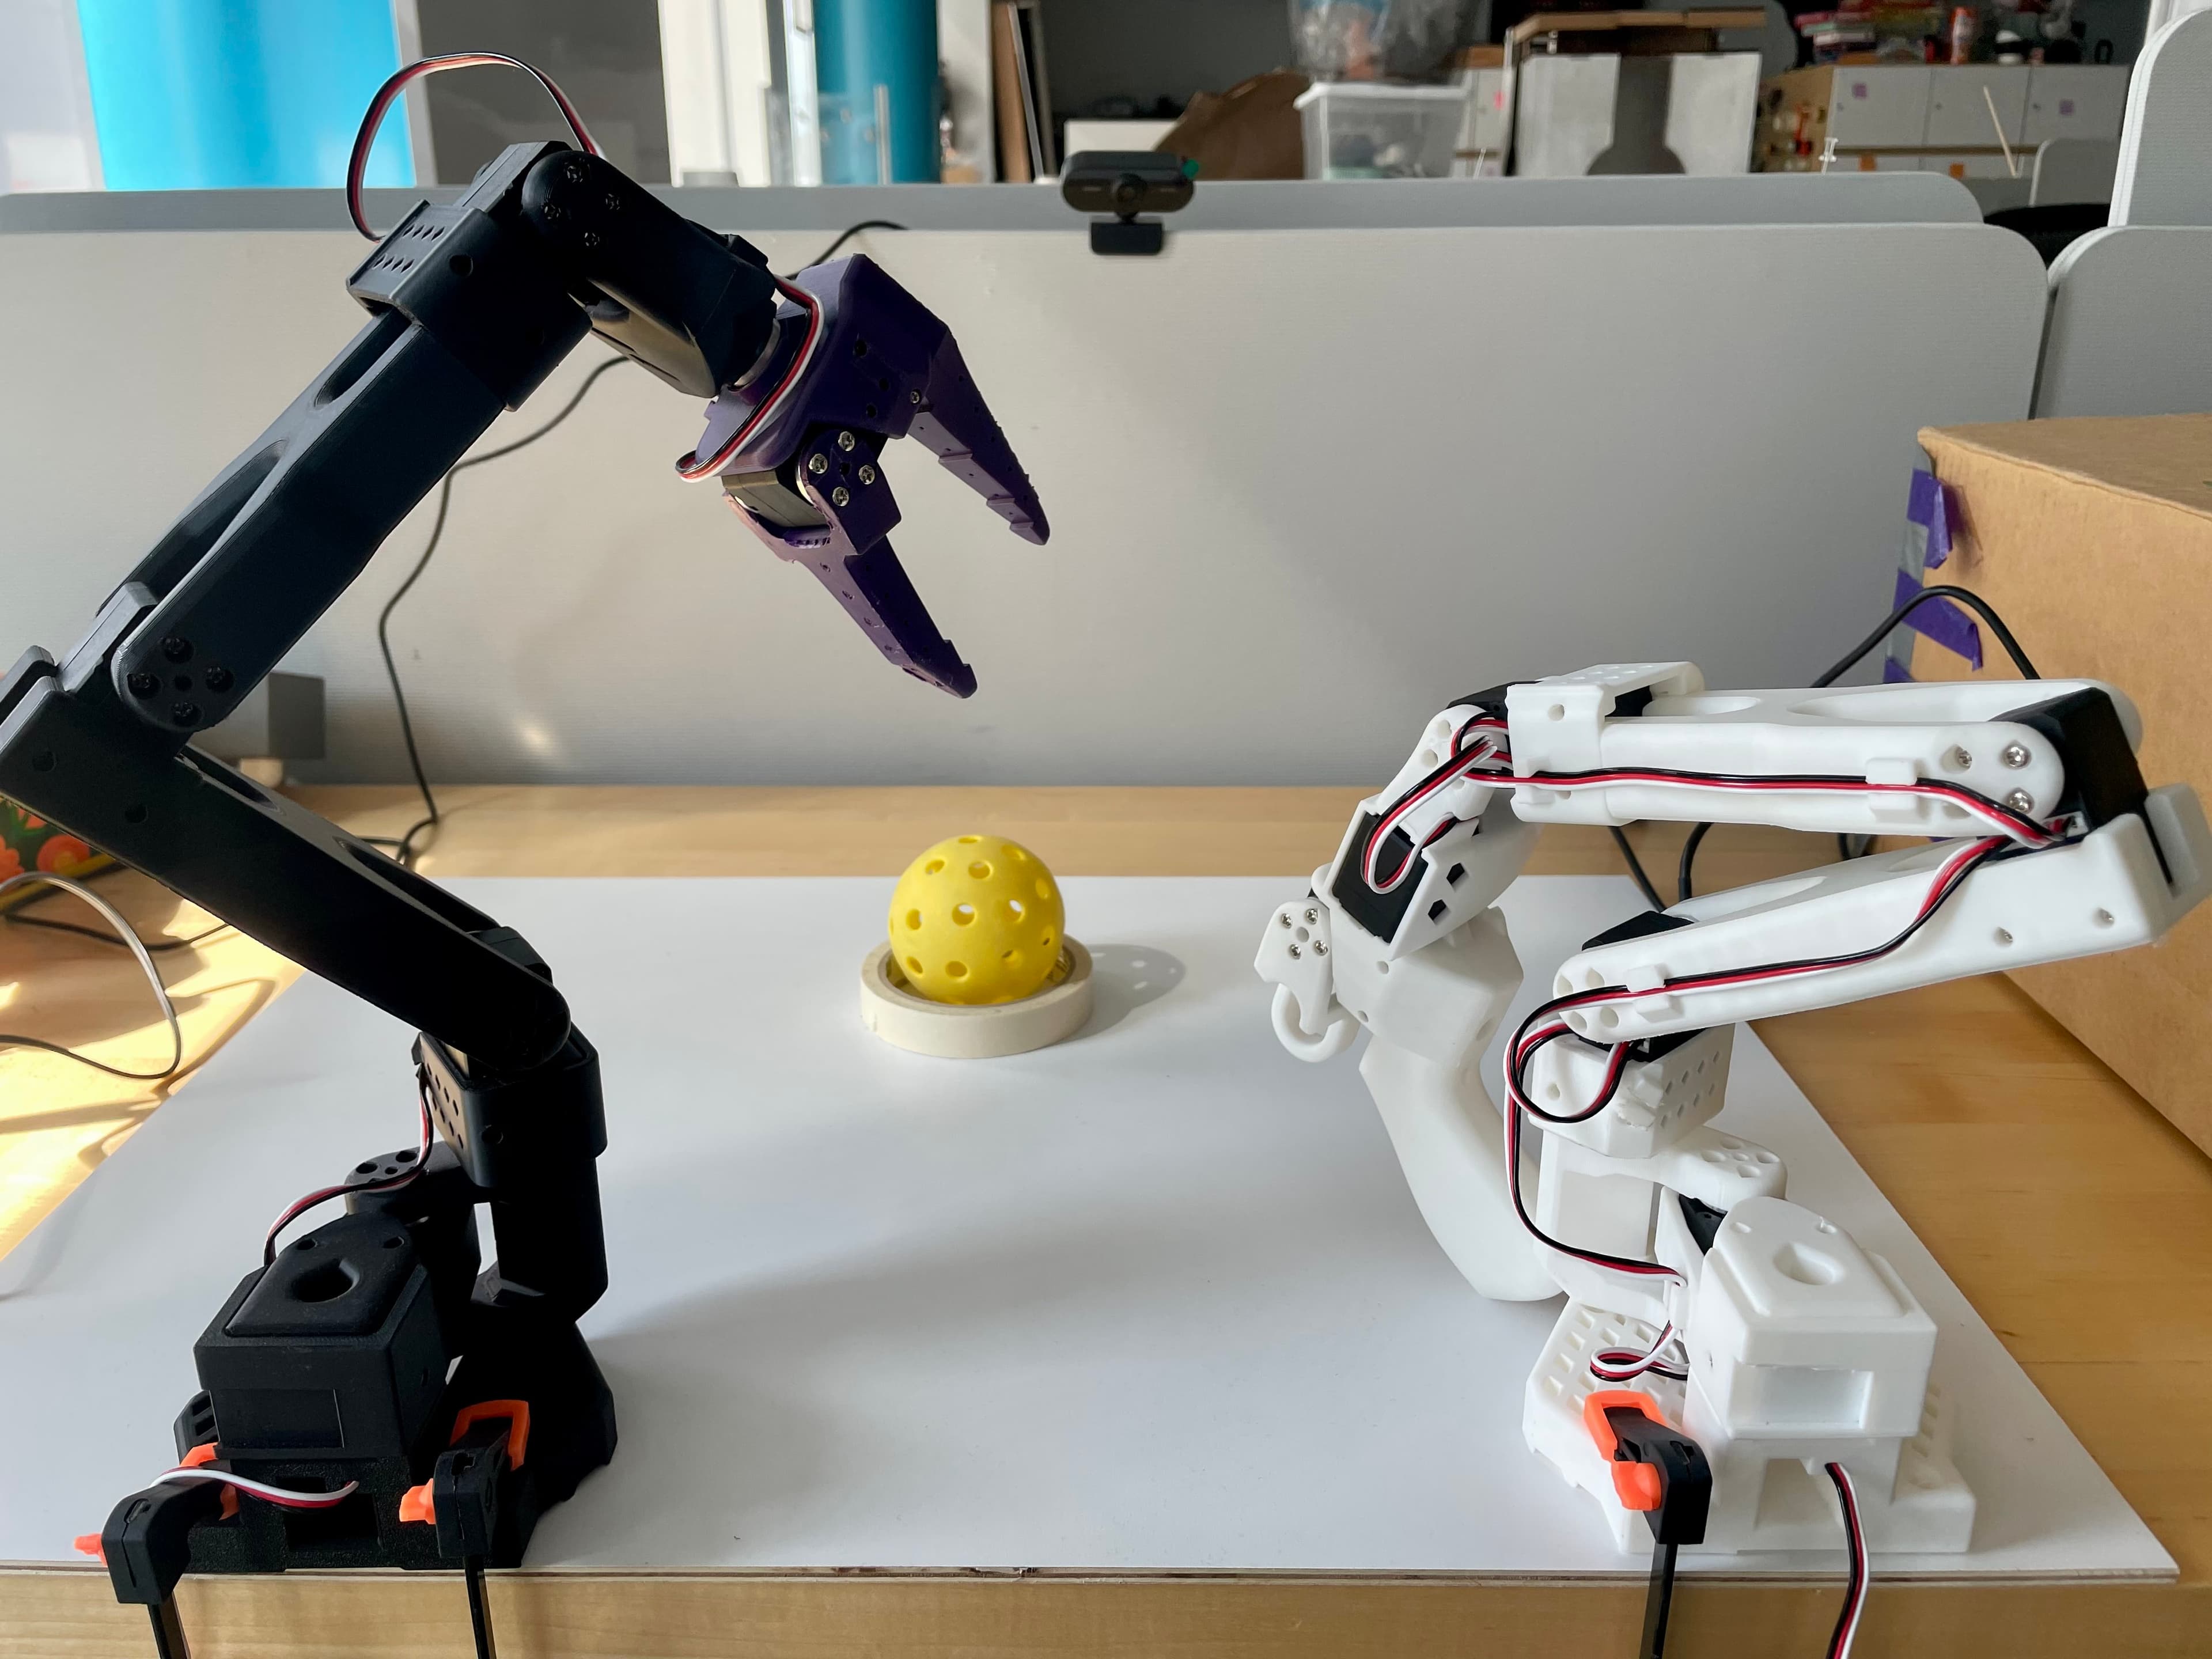
LeRobot SO-101 was a 2026 lab build based on Hugging Face's open-source robotics work. The SO-101 setup uses a leader and a follower robotic arm, which makes it possible to teleoperate the robot, collect demonstrations, and start thinking about robot learning through real physical interaction.
For this project, I focused on getting hands-on with the hardware: assembling the arm, understanding calibration, testing leader to follower control, and seeing how an open-source robotics stack can turn a small desktop arm into a learning system.
prototype demo
The most useful part of the build was seeing the system behave as a physical loop: a human moves the leader arm, the follower reproduces that motion, and those demonstrations become the raw material for training and evaluating robot behaviors.
SO-101 is designed as an accessible entry point into robotics: affordable hardware, open documentation, and a workflow that connects mechanical setup with data collection and learning.
I used the project as a way to understand how leader/follower control, calibration, teleoperation, and datasets fit together in a practical robotics workflow.
I'll add the full build notes, setup details, and more media once I organize the rest of the project story.